
In late September, Rodney Brooks published an essay that should be mandatory reading for anyone investing in humanoid robots, building them, or even casually thinking about either.
Brooks isn't some armchair critic. He co-founded iRobot (the Roomba people), built Baxter at Rethink Robotics, and spent decades running MIT's CSAIL lab. When he writes about robotics, you pay attention.
Rodney Brooks (Fortune)
His essay, Why Today's Humanoids Won't Learn Dexterity, makes three arguments that are worth pulling apart. The first raises a question that deserves expanding. The second is sharp first-principles observation. The third is something we have strong views on.
The Three Arguments
The entire value proposition of a humanoid robot is that it can do what humans do, in spaces designed for humans, with tools designed for humans. That requires human-like dexterity. And we are not close to building generalizable dexterous robots.
Brooks argues this is because the field is trying to brute-force the input-to-action mapping without understanding the underlying physics of manipulation. The dominant approach right now, Vision-Language-Action models (VLAs), attempts to make dexterity emerge from large dataset training and fine-tuned inference, the same approach that powers LLMs and large vision models. The added difficulty is that there's no touch/sensory-to-action equivalent of ImageNet out there to train these networks on at scale.
He might be right about this. The current talent density and venture capital flow is overwhelmingly pointed at VLA-based approaches, but nobody has cracked generalized manipulation yet.
Not in a science fiction way. In a simple physics way. A full-sized bipedal robot pumps enormous amounts of energy into staying upright. When it falls, that energy has to go somewhere. The scaling laws are brutal: a robot twice the size carries eight times the kinetic energy in a fall. These machines will hurt people, and they'll be a nightmare to certify for shared workspaces.
Human walking is elegant because our tendons act like springs, recycling energy and making it easy to absorb falls. Current humanoids use stiff actuators that counteract gravity by pushing hard into the ground via Zero-Moment Point control. When they fall, all that energy transfers instantly. Energy-recycling tendons for humanoids are being researched (see this presentation for the technical details), but production hardware is nowhere close. Even just standing still requires constant current through the actuators, with overheating as a real risk.
This is where Brooks gets genuinely interesting. He predicts we'll soon have plenty of "humanoid" robots in our factories and homes, but they won't look human at all. Wheels instead of legs. Multiple arms. Sensors in unusual configurations rather than faces with eyes. The label might stick even as the form factor evolves away from human morphology entirely.
The logic is straightforward: optimize the form factor for fitness to the task, stop caring about human similarity. And we're aggressively in agreement.
Humanoids Raise Money. Semi-Humanoids Make Money.
Here's the uncomfortable observation: the recent wave of massive capital allocation into Western, freakishly-human-like humanoids looks optimized for fund economics, not commercial viability.
Mega-funds need to deploy huge amounts of capital quickly. Very few companies can claim on a pitch deck that their total addressable market is "literally any physical task humans can do." That's the kind of narrative that justifies multi-billion dollar valuations before a single production unit ships. Meanwhile, their bipedal prototypes generate mostly headlines and TVPI.
Something quieter is happening alongside the hype. Wheeled robots and mobile manipulators are starting to generate actual revenue while their bipedal cousins still chase demos.
Unitree just announced the G1-D, a humanoid torso on wheels with a full software suite for data collection and world model integration. They traded bipedal locomotion for 3x the battery life (six hours, which is more than a MacBook running Matlab) and the stability needed for reliable operation. It's not as flashy, but it works.
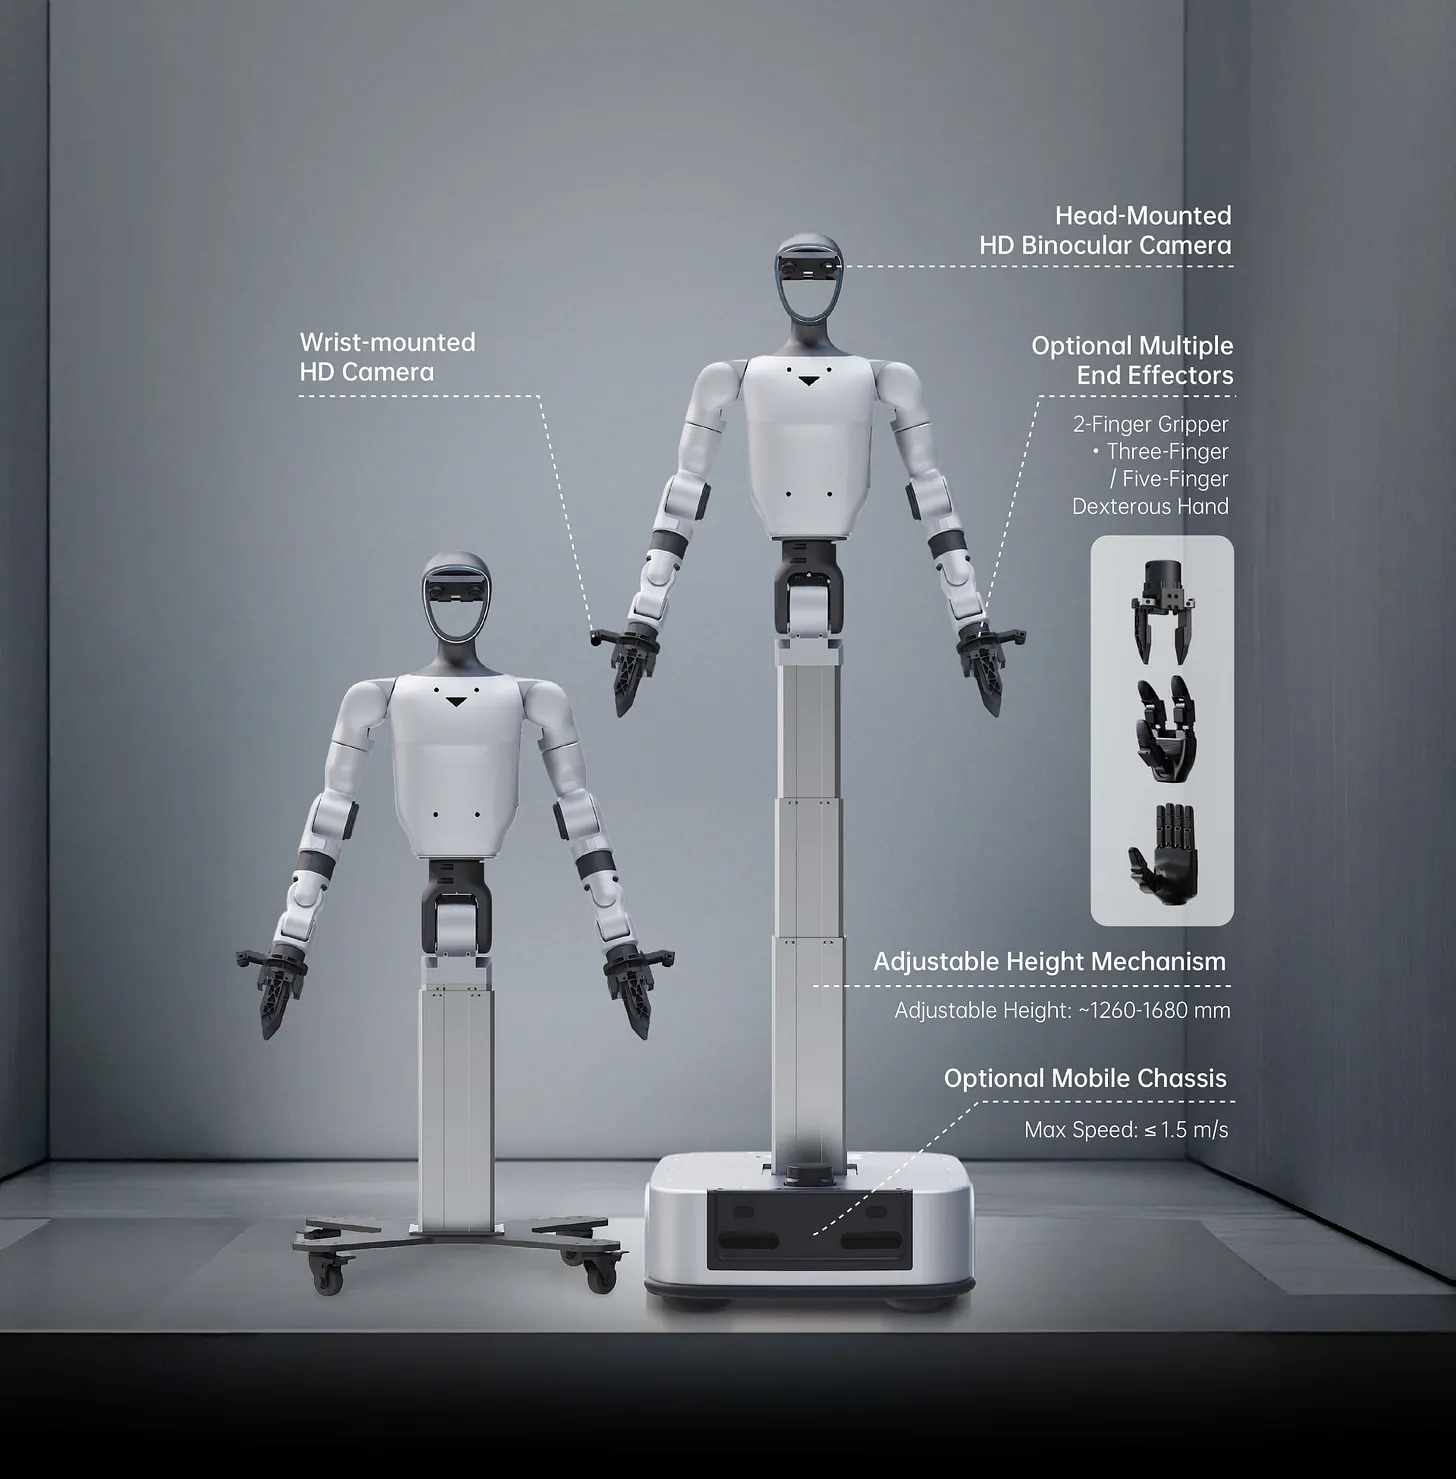
G1-D's configurations. The wheeled base trades bipedal flashiness for battery life, stability, and deployability. Semi-humanoids bypass almost entirely the safety certification nightmare that haunts legged machines.
Join the construction briefing people read to stay one step ahead
Get sharp construction tech updates, operator insight, and market signals in your inbox.
Join 3000+ ReadersSemi-humanoids are quicker to deploy, far more battery-efficient, and sidestep the safety certification concerns that plague legged machines. And as you'd expect in a market this hungry for assets, they're attracting serious capital too.
Sunday Robotics and the Stanford connection
Sunday Robotics came out of stealth with that $35M raise and a founding team worth knowing. Tony Zhao is one of the authors of ALOHA, the Stanford project that proved semi-dexterous manipulation could be done with cheap hardware, then open-sourced everything. At least four founders we know of are building on that platform. Cheng Chi is the lead author of UMI, another open-source Stanford project focused on gathering manipulation data in real environments without the robot needing to be present (here's what that looks like in practice).
What's compelling about both founders is that they cut their teeth on cheap, open-source hardware running software platforms optimized for data collection and interoperability. That background matters, because competing with Asian robotics companies long-term will require exactly that mentality. Chinese humanoids are already cheap and mass-produced, and despite claims that Western companies build better software, Unitree's open-source software stack is a key reason for its global lead in sales of quadrupeds and humanoids to research labs worldwide.
Humanoids raise money. Semi-humanoids make money. The form factor that wins won't be the one that looks most human. It'll be the one that's most useful.Bricks & Bytes Editorial
The Dexterity Problem: End-to-End vs. Traditional Robotics
Whether you prefer humanoids or less-human form factors, you still have to solve dexterous manipulation if you want these machines to become standard equipment in factories, warehouses, hospitals, and homes. This brings us back to Brooks' first argument, and into one of the most important debates in robotics right now.
| Approach | How It Works | Strengths | Weaknesses |
|---|---|---|---|
| End-to-End (E2E) Learning | Train neural networks on massive datasets of demonstrations, corrections, and self-practice to learn generalized manipulation policies. | Potential for generalization across tasks. Rapid improvement curve. Less manual engineering per new task. | Not interpretable. Hard to debug failures. Reliability far below production thresholds. Limited by available training data. |
| Traditional / Deterministic | Explicitly program state machines and control logic for each task. Every edge case handled with specific engineering. | Debuggable. Predictable. Certifiable. Trusted in production environments today. | Visible ceiling. Every new task needs new engineering. Nothing generalizes. Scaling is slow and expensive. |
Some impressive research results are coming from teams applying end-to-end learning to generalized manipulation policies. The pi*0.6 announcement from Physical Intelligence is the best current demonstration of what's possible when you combine imitation and reinforcement learning. Their RECAP framework trains robots with demonstrations first, then corrections from human operators, then autonomous practice. The progress is undeniable.
But the task-specific throughput, reliability, and ease of deployment achieved by these systems are nowhere near what real-world operations require. You can't accept significant downtime from a machine bought to increase efficiency. And the bottleneck is interpretability. VLAs use the transformer architecture that powers LLMs, which aren't interpretable. In both development and production, it's extremely difficult to troubleshoot why an E2E system is failing. All you can do is try progressively cleverer network and training architectures, hoping the next iteration yields lower failure rates. Getting stuck in local maxima is easy.
The open-source ecosystem is accelerating things
Hugging Face's LeRobot has become something like the Transformers library for robotics: a unified framework integrating state-of-the-art models from Physical Intelligence, NVIDIA, and others. After acquiring Pollen Robotics, they're even selling open-source hardware. The full stack is becoming accessible to developers. I actually just bought one.
And then there's the data angle. Build AI recently released 100,000 hours of first-person video footage from factory workers performing skilled tasks. Over 10 billion frames. The thesis is that egocentric human video could be for robotics what internet text was for LLMs: a massive, passively-collected training corpus that could unlock generalization. More data doesn't solve the interpretability problem, but it does improve the odds of landing on progressively better local maxima.
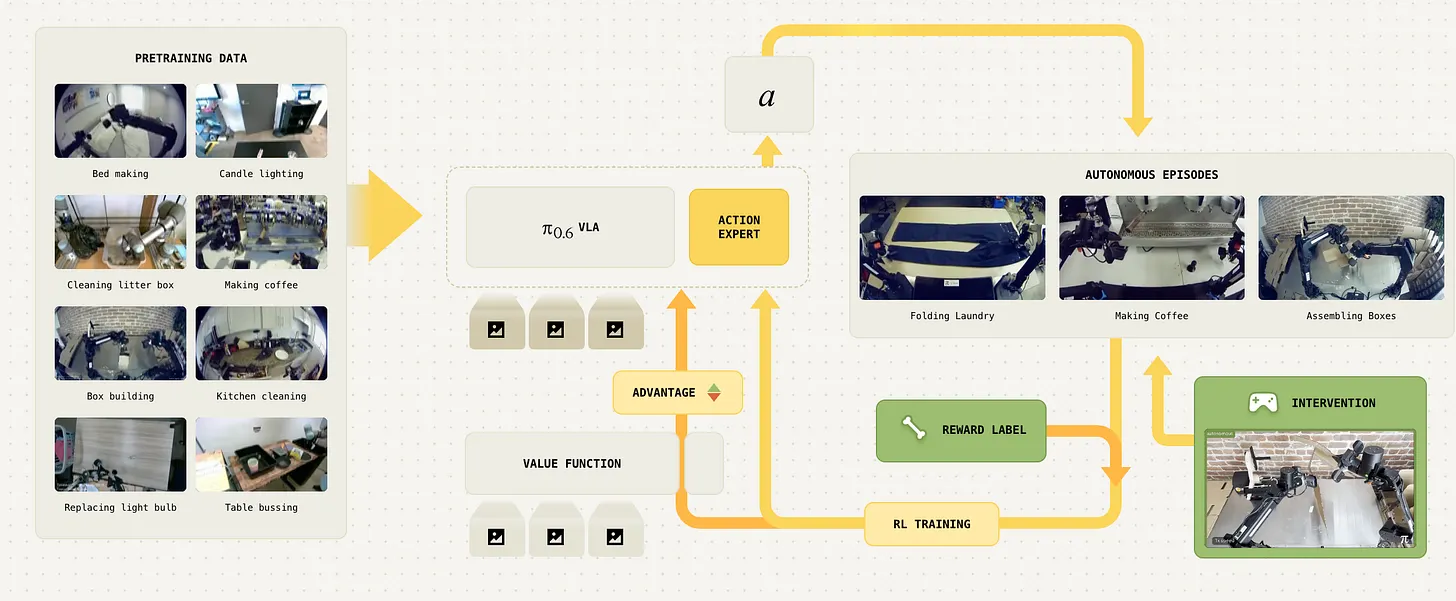
The path forward isn't choosing between traditional and end-to-end approaches. It's building infrastructure that lets you implement E2E progressively, with interpretable fallbacks for when the learned system's confidence drops.
The Hybrid Architecture That Actually Ships
Most enterprise robotics deployments today run on traditional approaches. And for good reason: you can debug a state machine. You can't debug a neural network that learned to fold laundry from watching humans. But the ceiling on traditional methods is clearly visible. Every new task needs new engineering. Every edge case needs explicit handling. Nothing generalizes.
The answer isn't picking a side. It's building infrastructure that lets you implement end-to-end capabilities progressively.
The winners won't be pure end-to-end or pure traditional. They'll build hybrid architectures where traditional systems provide the reliability floor and learned systems provide the capability ceiling. The form factor won't be the most human-looking. It'll be the most useful. And the business model won't be selling robots. It'll be delivering outcomes.
For more on robotics, AI, and what's actually working in the built world, listen to the Bricks & Bytes podcast or browse our technology coverage.





